Robot management
Manage robots by adding robot groups.
Add, delete and edit robot groups.
View details for the selected robot, including its model and IP address.
Products
Connects robot management, route management and task scheduling to coordinate multiple robots.
Talk to an expertThe JINSYS Traffic Control System (TCS) integrates intelligent robots and factory automation equipment for coordinated operation and scheduling. Efficient global collaborative planning algorithms handle multi-robot pathfinding and traffic control to avoid congestion and prevent and resolve deadlocks.
The system consists of an interactive interface and a backend scheduling service. Robot, map and station management through the interface is automatically synchronized with the scheduling service.
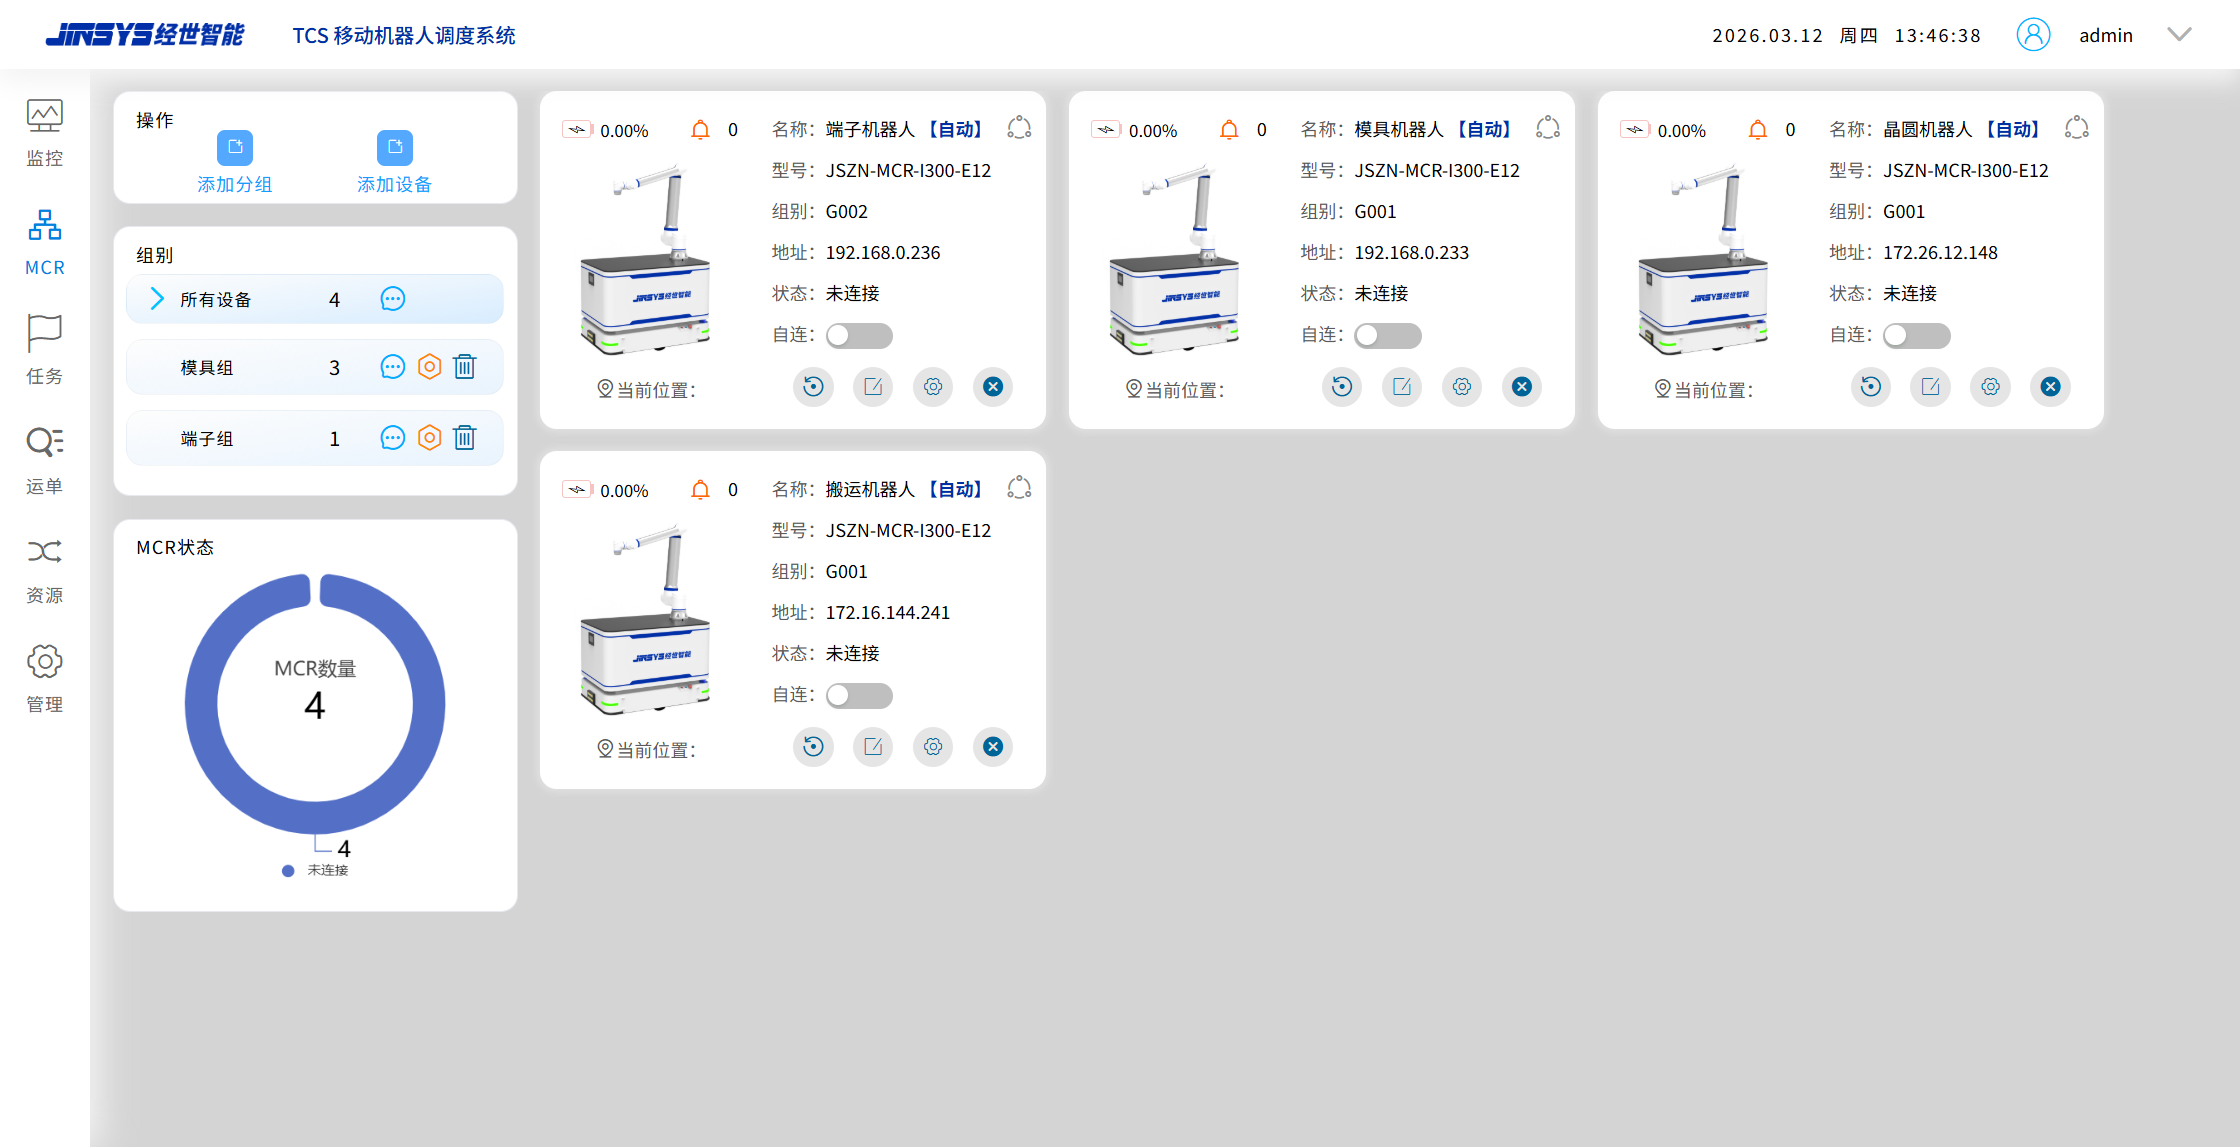
Manage robots by adding robot groups.
Add, delete and edit robot groups.
View details for the selected robot, including its model and IP address.
Configure station properties.
Manage charging and waiting stations, orientation, categories and obstacle avoidance settings.
Assign robots to selected charging, working or parking stations.
Configure communication between working or waiting stations and other automation equipment.
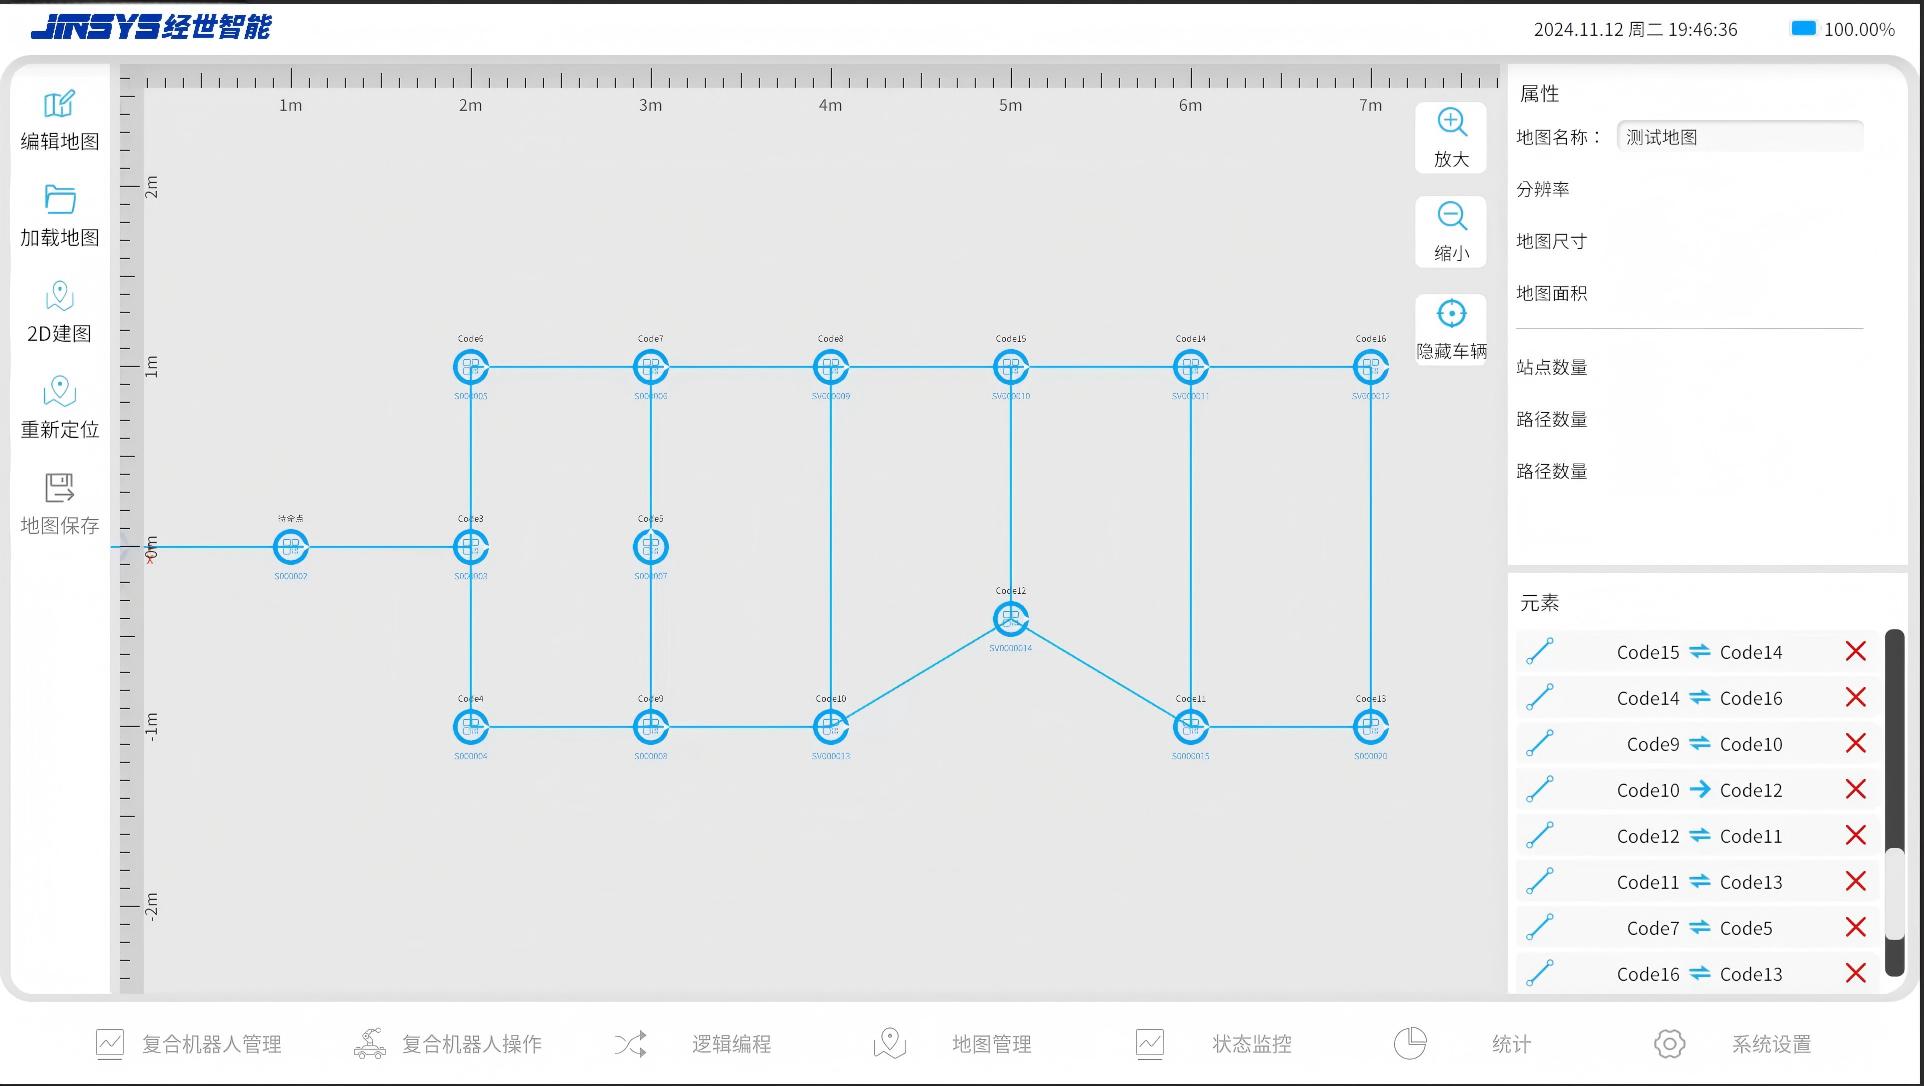
After the robot operating system creates a map, its data is transferred to the scheduling system through an interface.
Each map has a unique identifier and can be assigned to multiple robots.
Display and handle warnings and errors from the current interface.
Display errors from the backend scheduling service.
Display mobile manipulator errors and alarms.
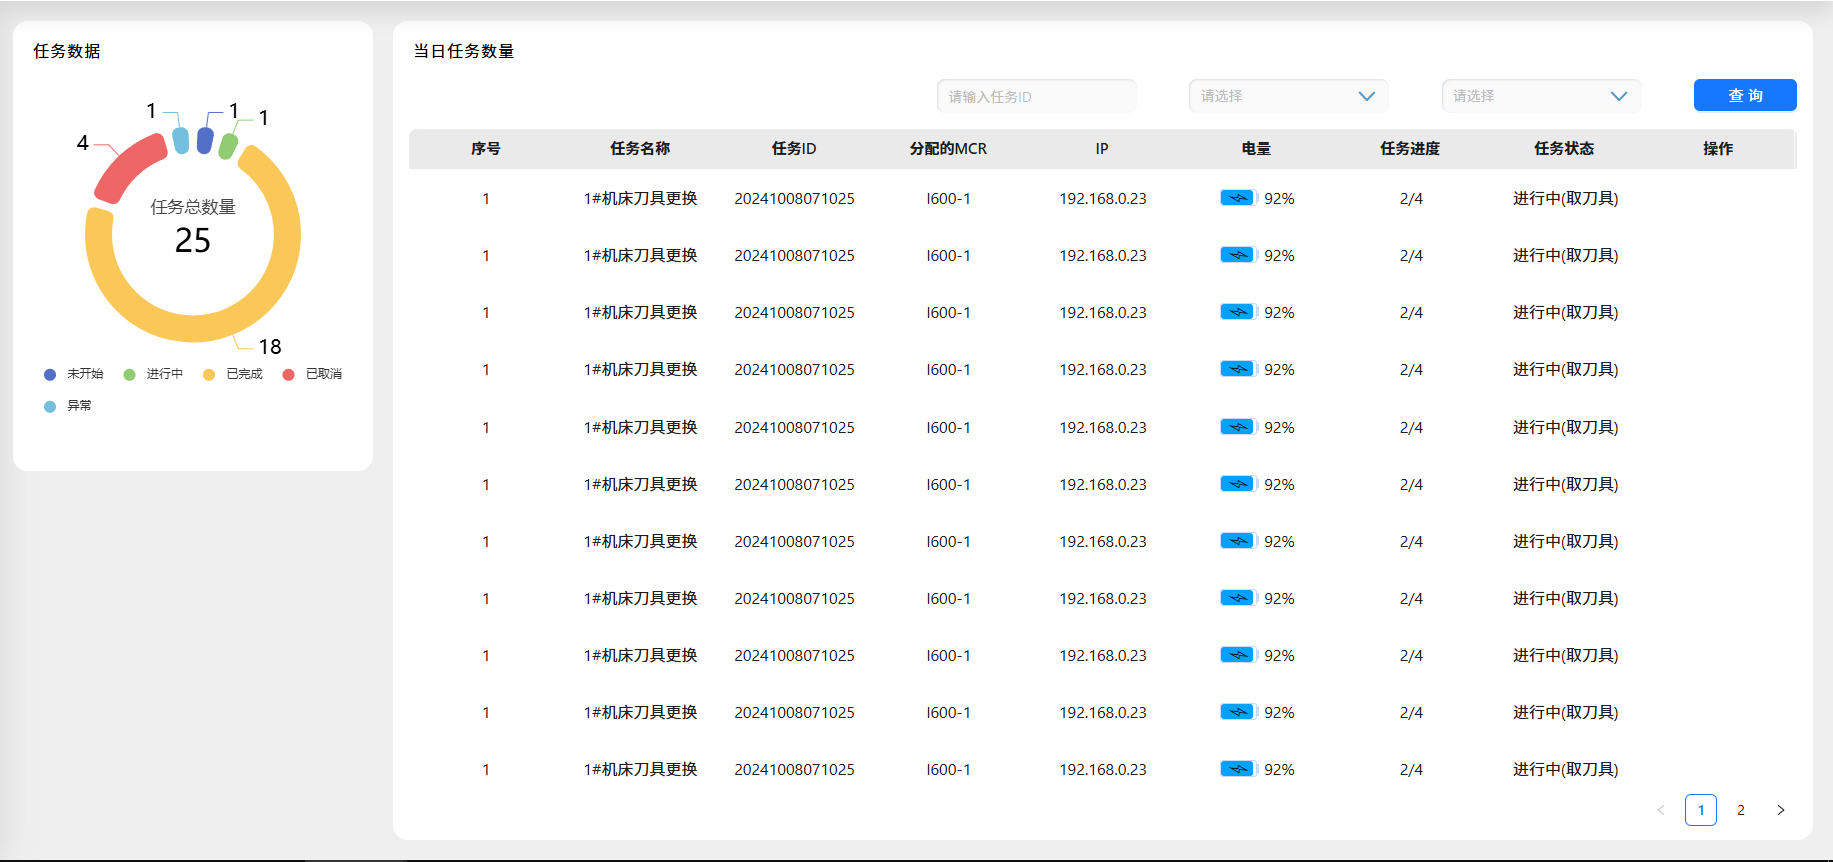
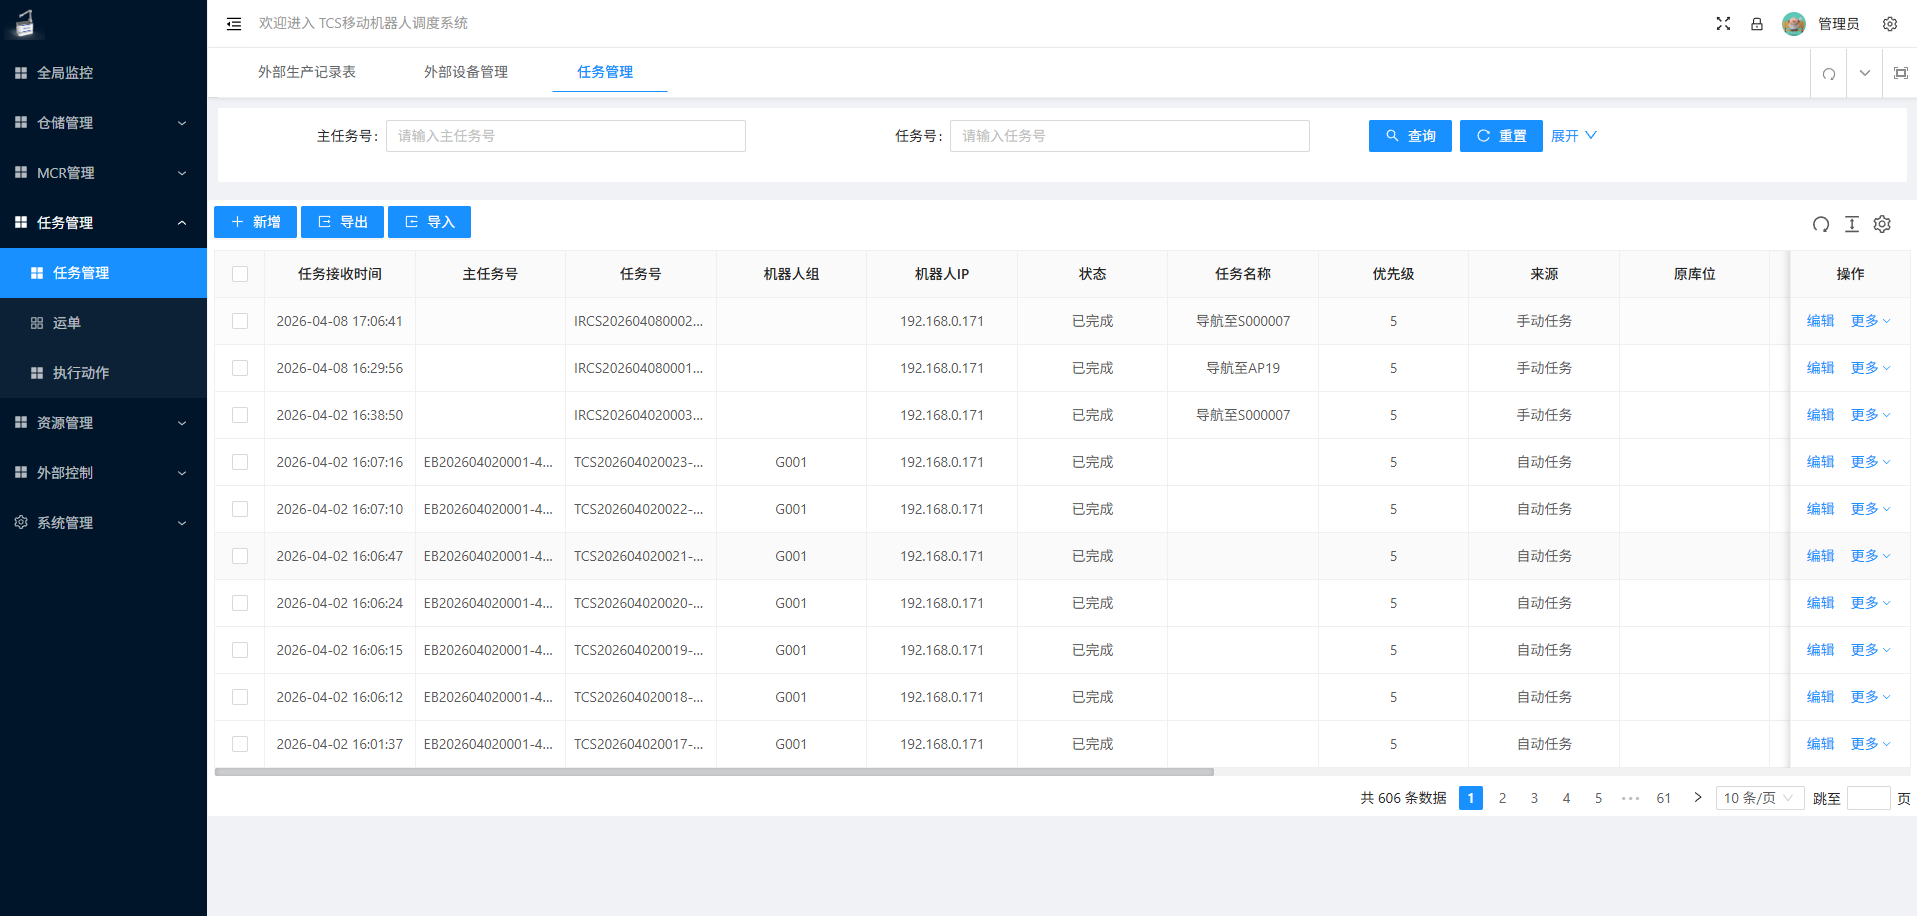
Connect to upstream WMS, MES and central control systems through APIs.
System tasks include navigation, arm actions and Master programs.
Navigation tasks move the mobile manipulator to a specified location.
Arm actions perform specific work tasks.
Master programs execute the robot operating system's programmed logic.
The transport order list shows order numbers, assigned mobile manipulators, order details, task types, task status and start times.
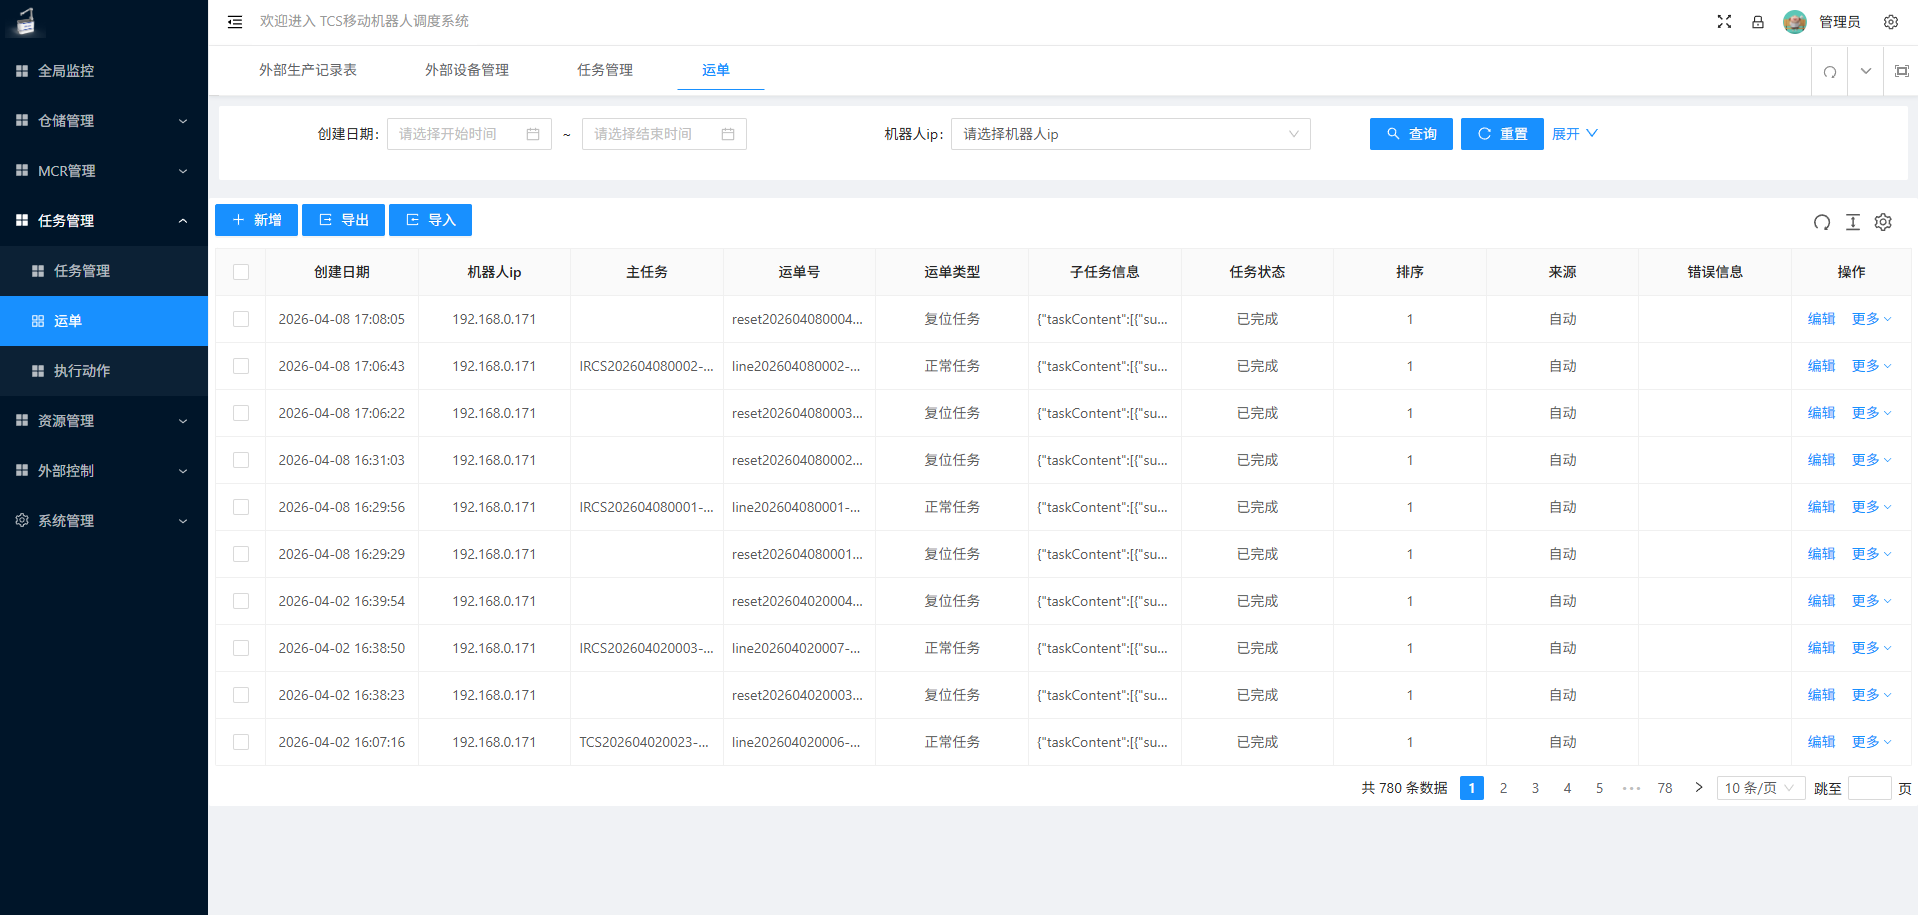
Connect to upstream WMS, MES and other systems through APIs, supporting both initiated and received communications.
Exchange data with elevators, automatic doors and production equipment. Communicate with PLCs over Ethernet using Modbus TCP.
The interface includes robot operation controls and an information list, with options to acquire or release control over robot behavior and status.
The transport order list includes all completed and active orders, showing order IDs, robot status, start times and elapsed time.
Record all actions performed by the account, API calls to upstream management systems and communication with downstream equipment.
Add, edit and remove system user identities, roles and permissions.
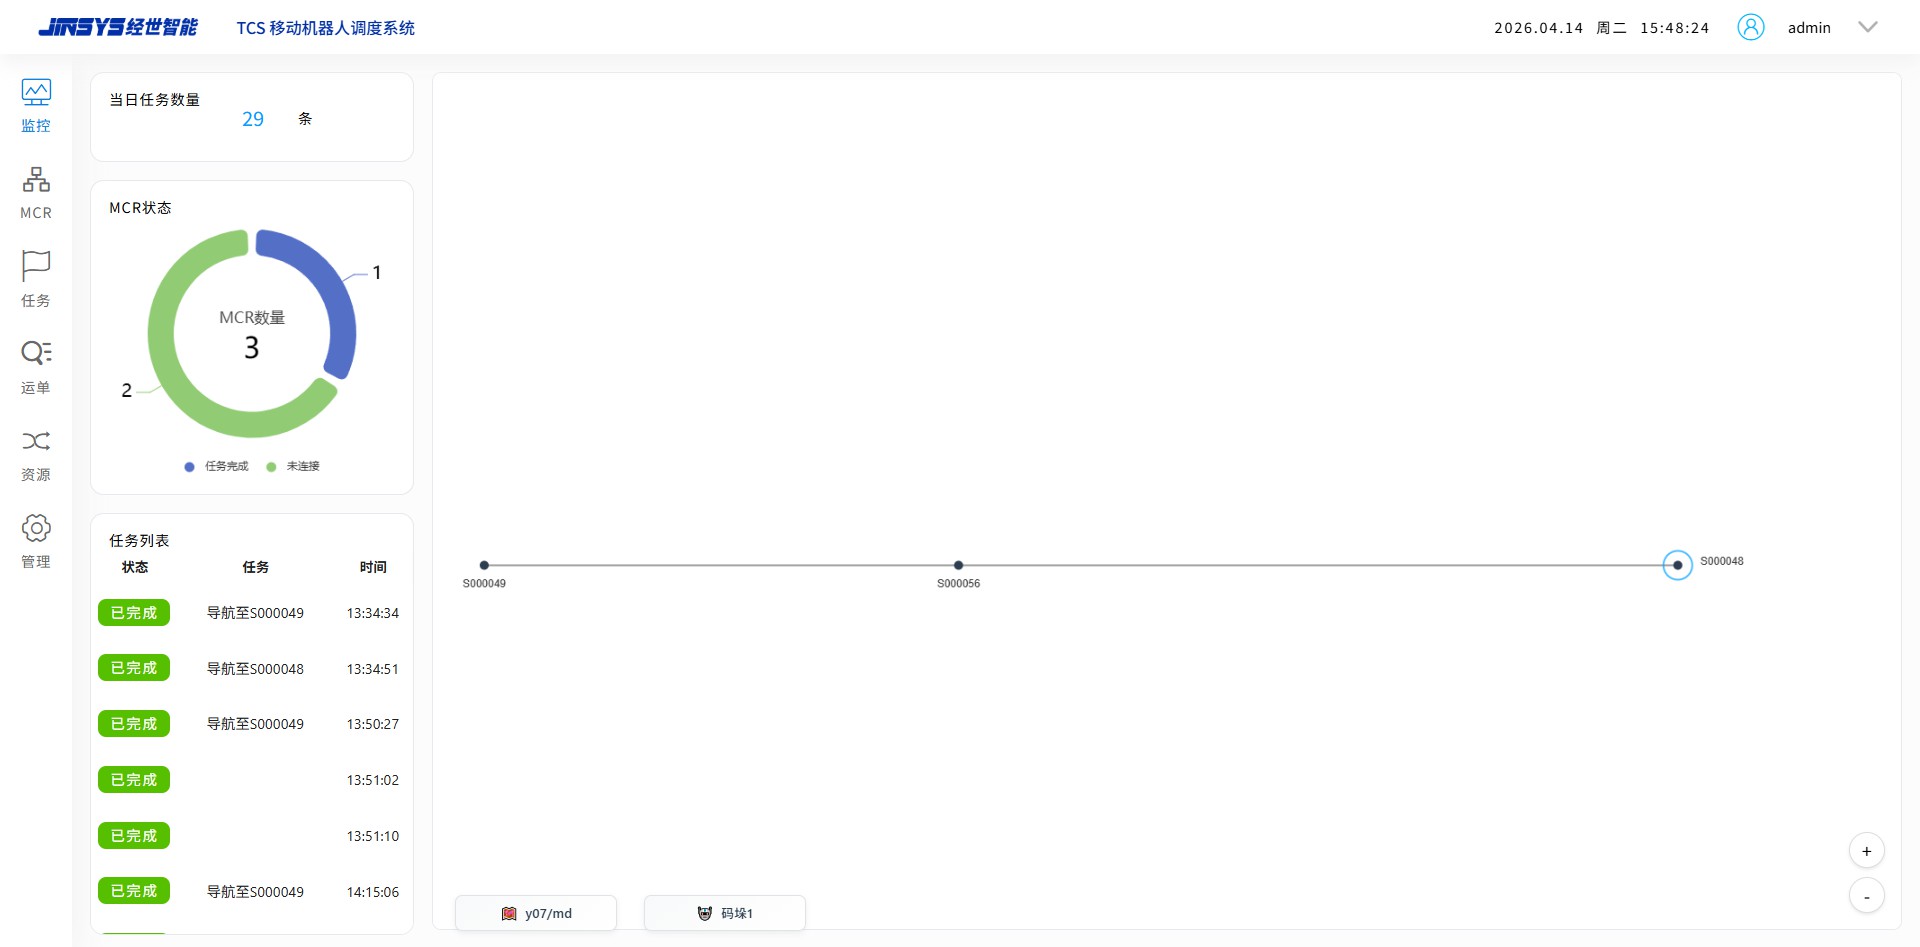
Monitor robot routes and stations, operating status, activity and resource usage.