Technology
Digital twin planning
Combines planning and simulation for smart factories, manufacturing lines, warehousing and logistics.
Talk to an expert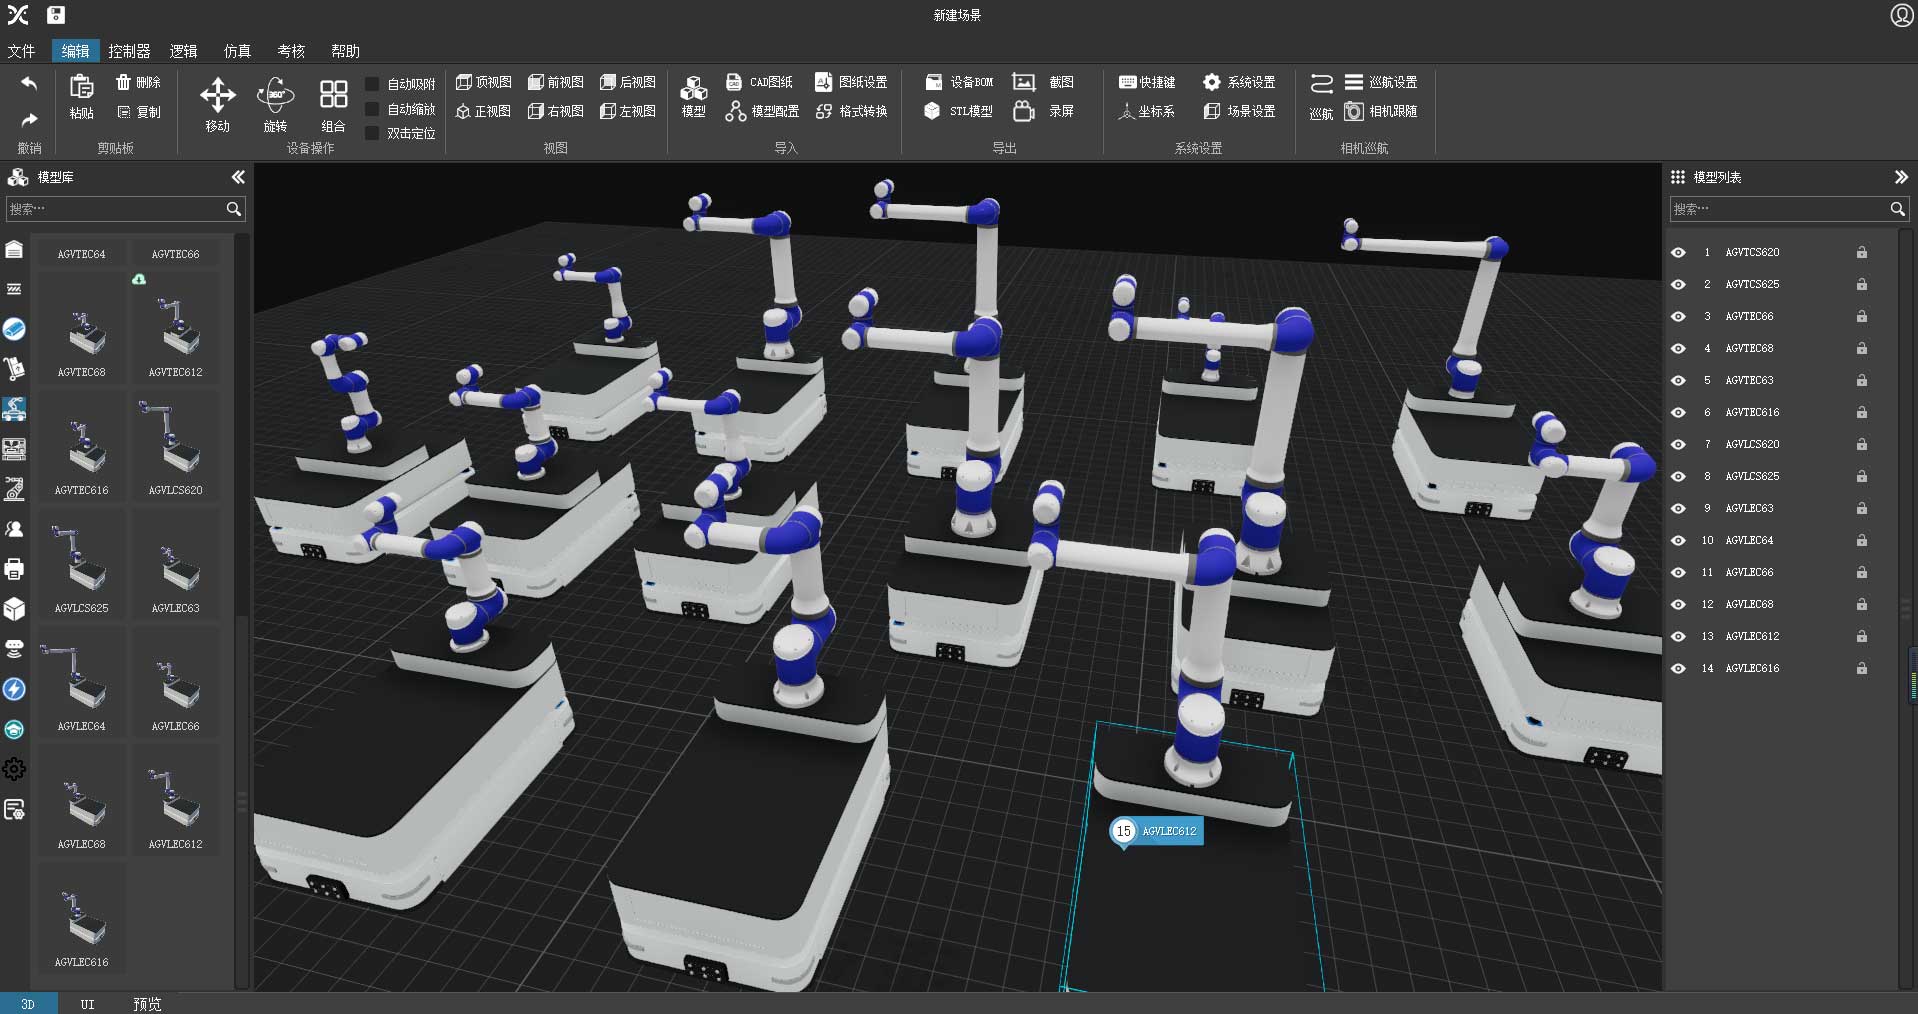
Twin Elephant Digital Twin Planning Platform
Twin Elephant is an integrated planning and simulation platform developed by Shandong Jingshi Intelligent Technology Co., Ltd. for smart manufacturing projects, including smart factories, production lines, warehousing and logistics.Feature highlights
A standard JINSYS mobile manipulator model library for faster selection
Includes JINSYS full range of standard mobile manipulator models, with I-, T- and L-type chassis and arm payloads from 3 kg to 25 kg. Build scenes by dragging and dropping models.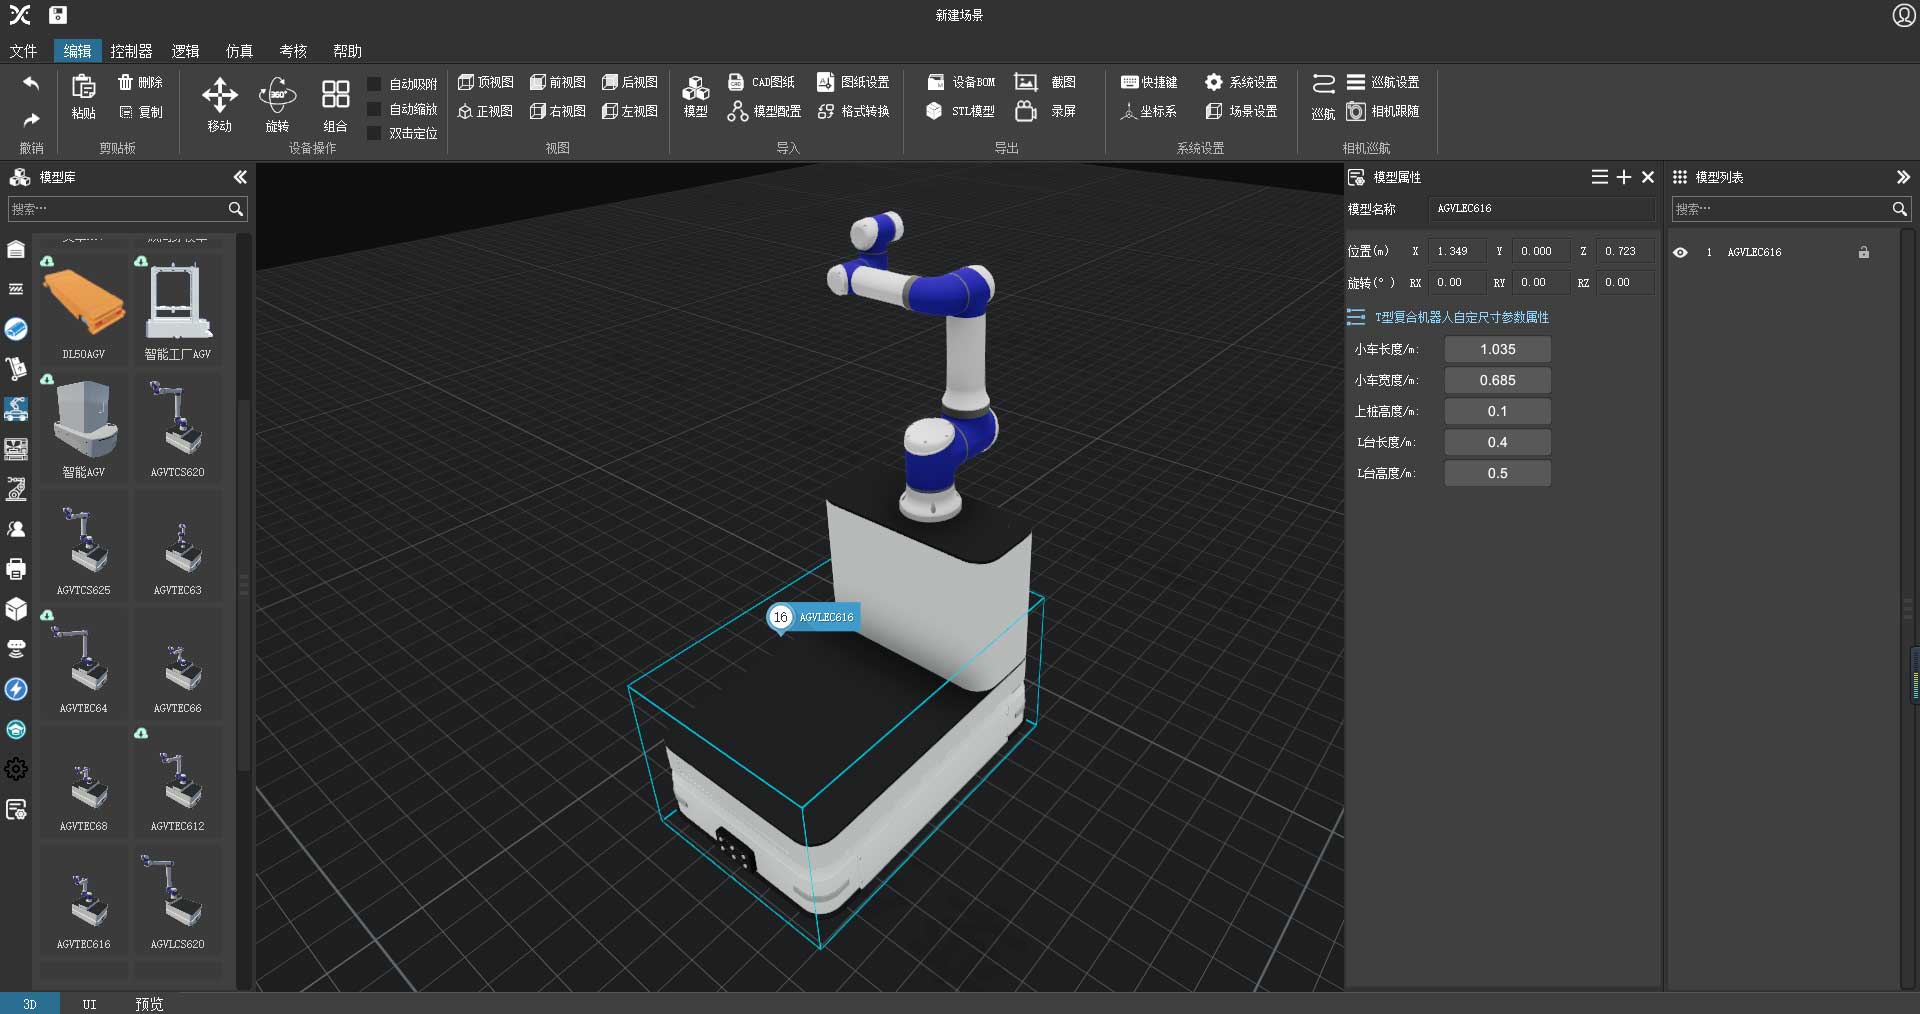
Customize chassis dimensions for specific applications and vehicle requirements
Adjust the dimensions of a standard chassis model to meet the space requirements of a particular application.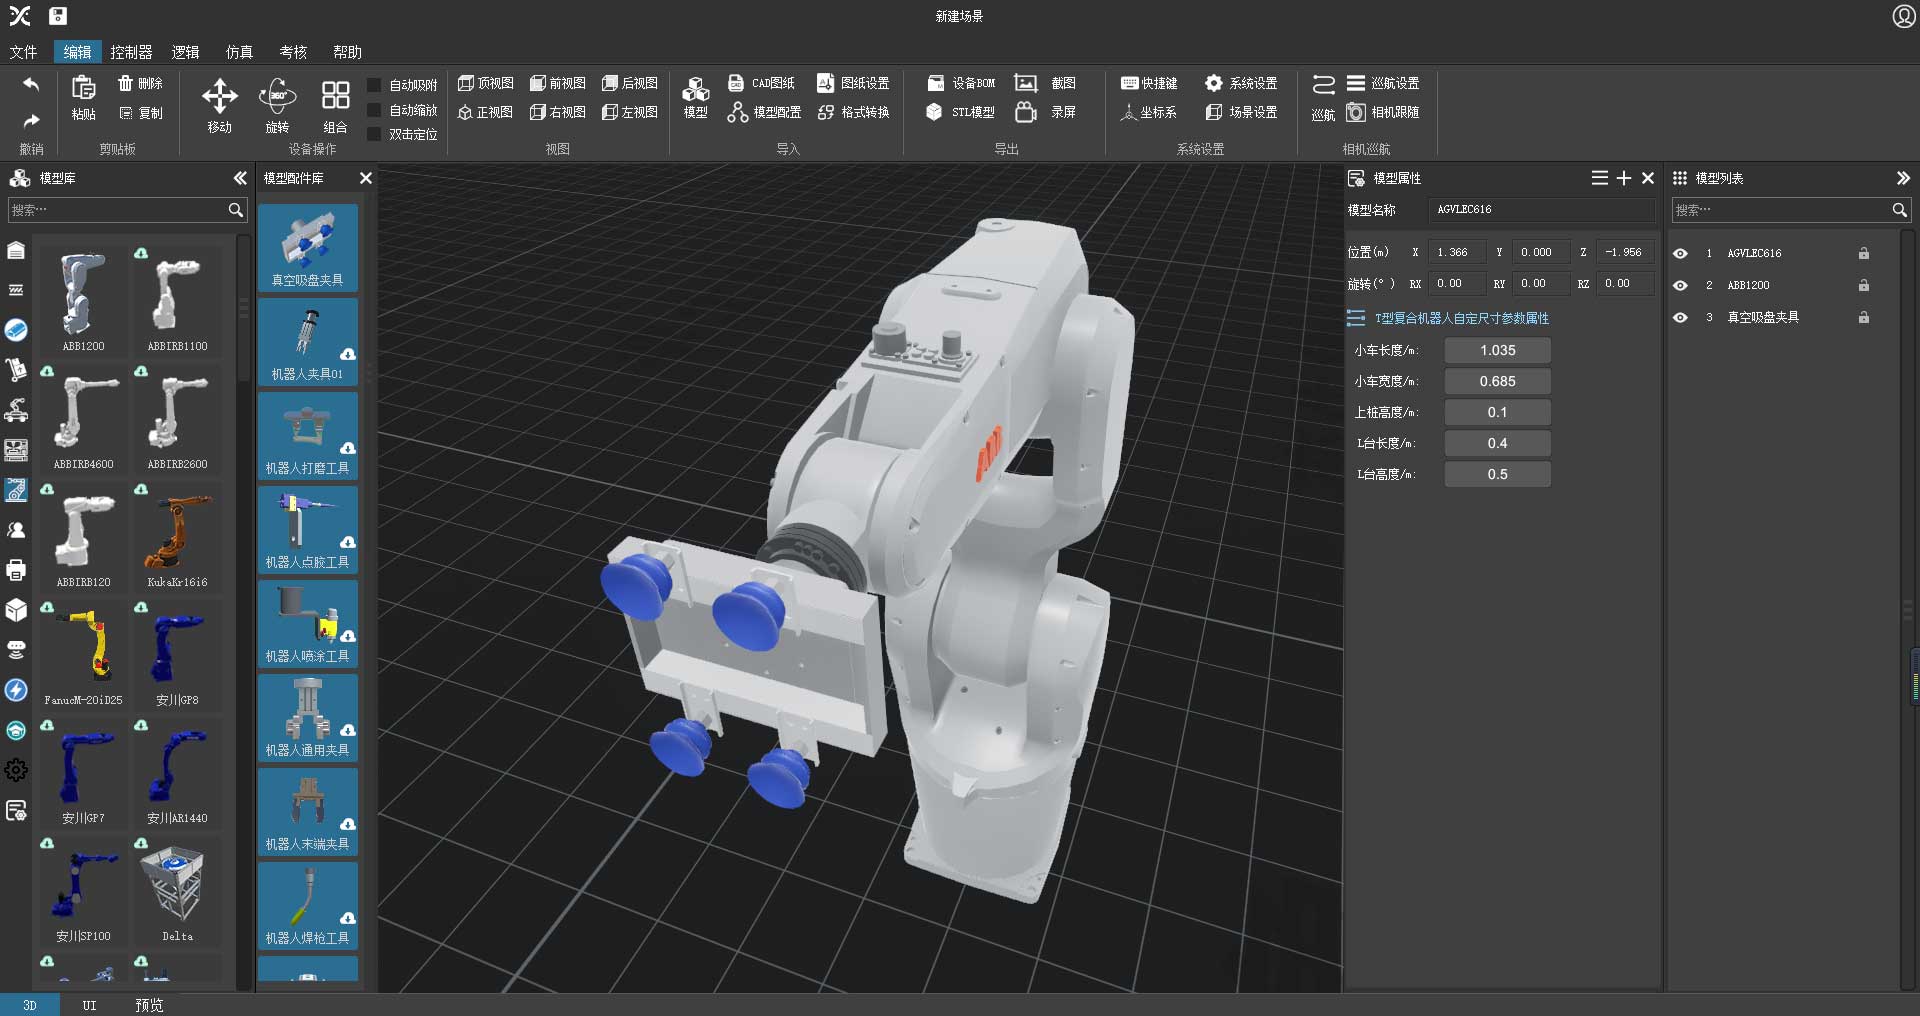
Choose standard end tools and backpack modules from a secondary library
The mobile manipulator component library includes standard grippers and backpack modules. Drag components onto the arm end effector and run dynamic motion simulations.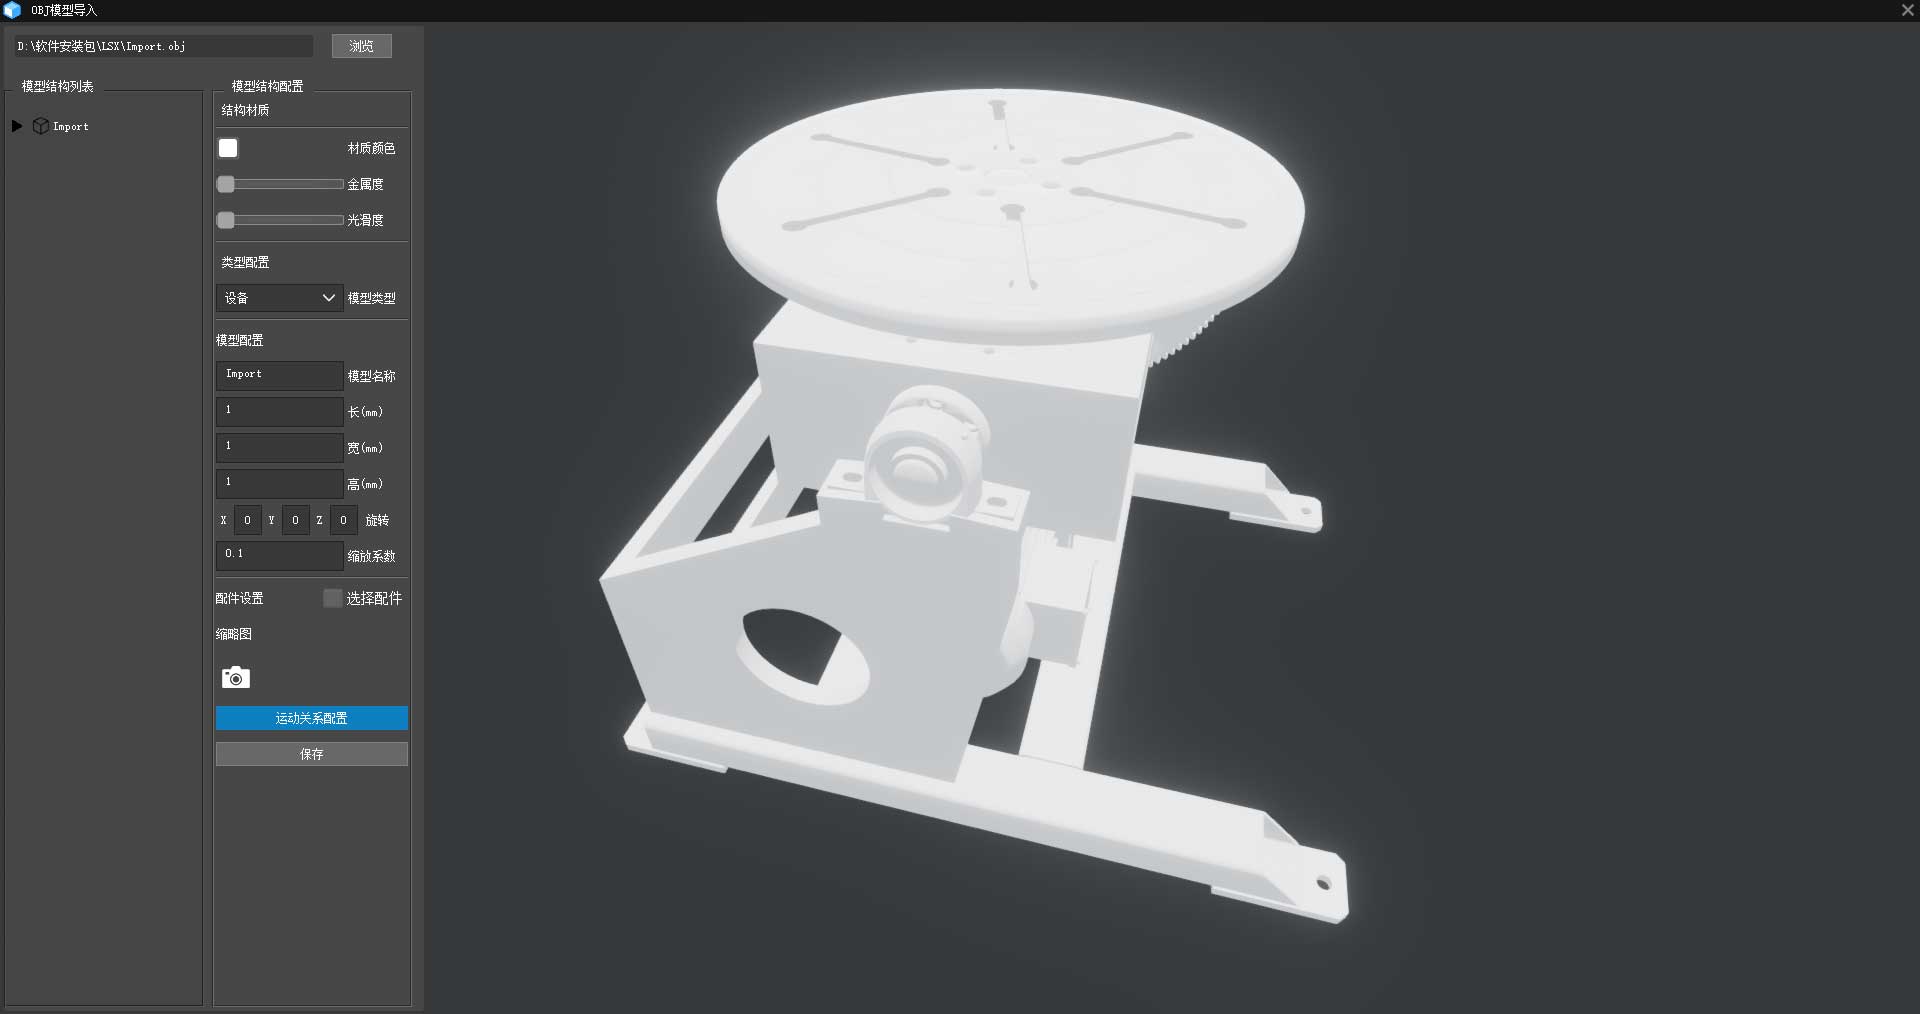
Import external models to customize end tools and backpack modules
Import custom models with support for model conversion, appearance customization, parameter configuration and motion mechanisms.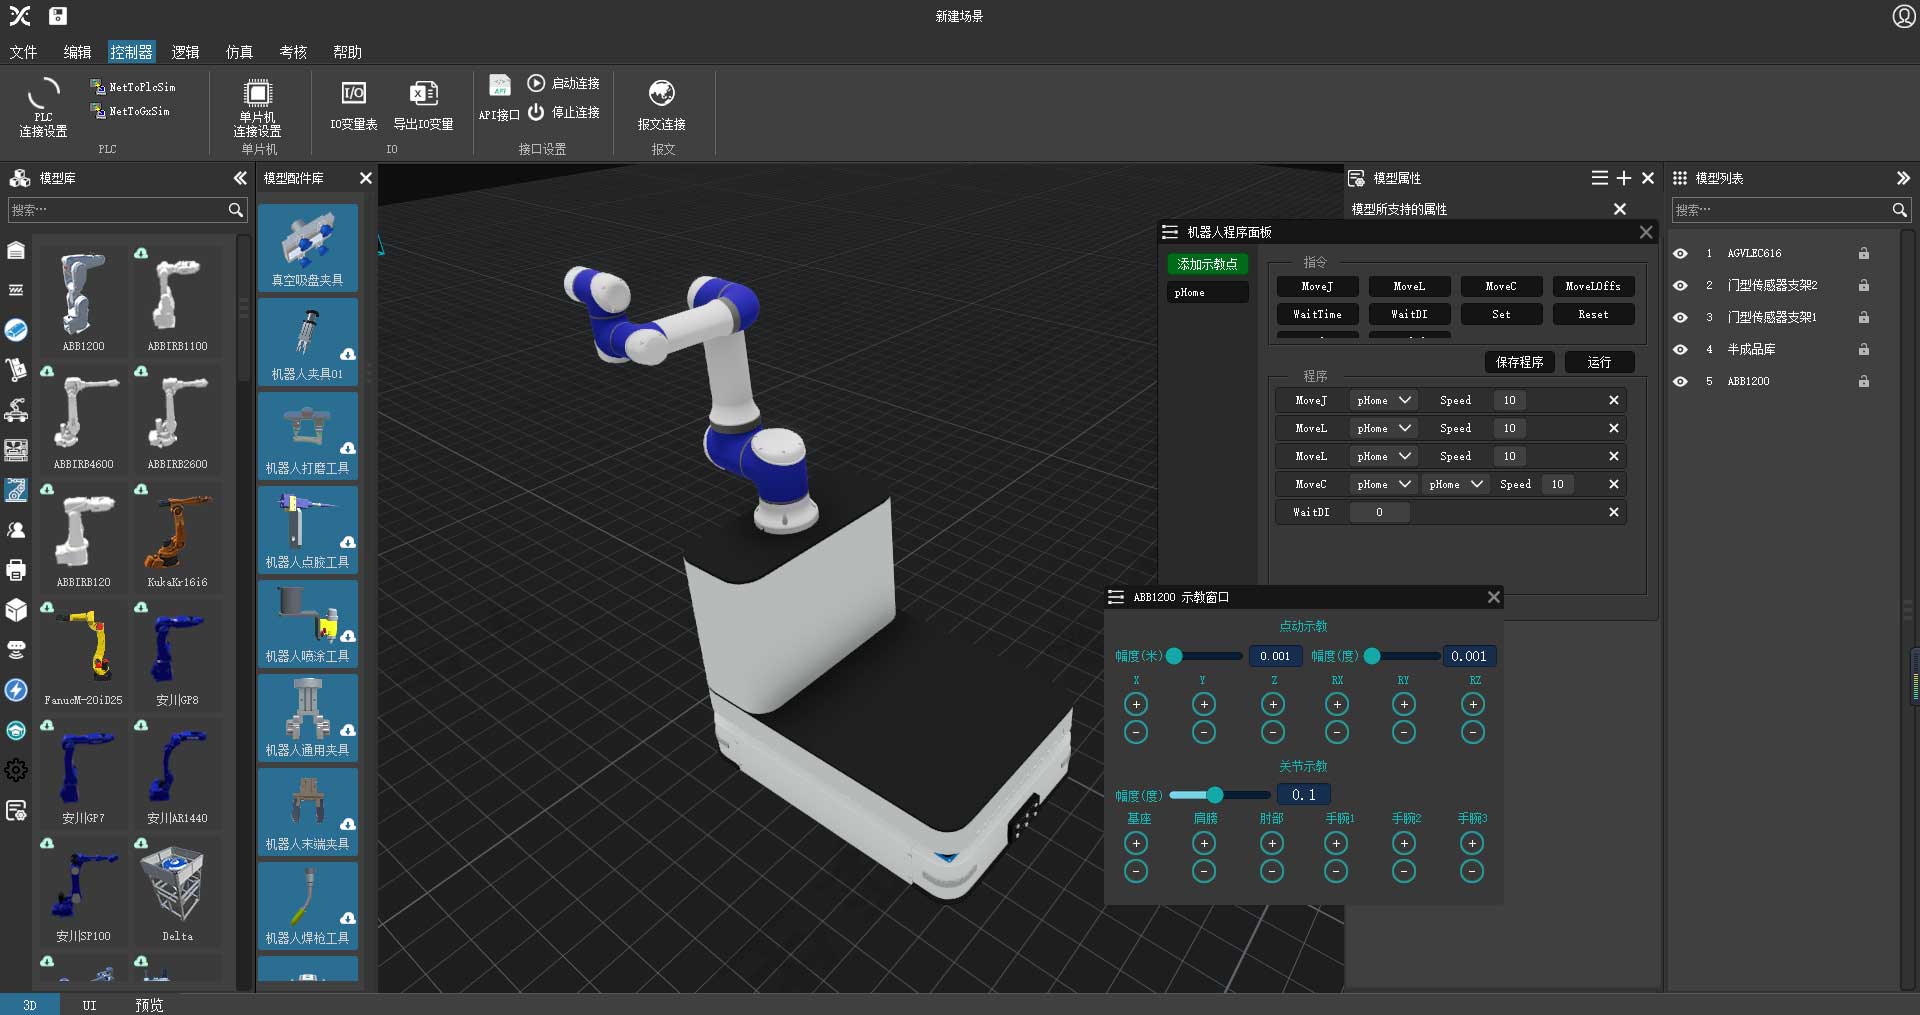
Offline arm programming with forward and inverse kinematics
Built-in forward and inverse kinematics, trajectory interpolation and speed planning algorithms allow offline programming with a virtual teach pendant to validate program logic in advance.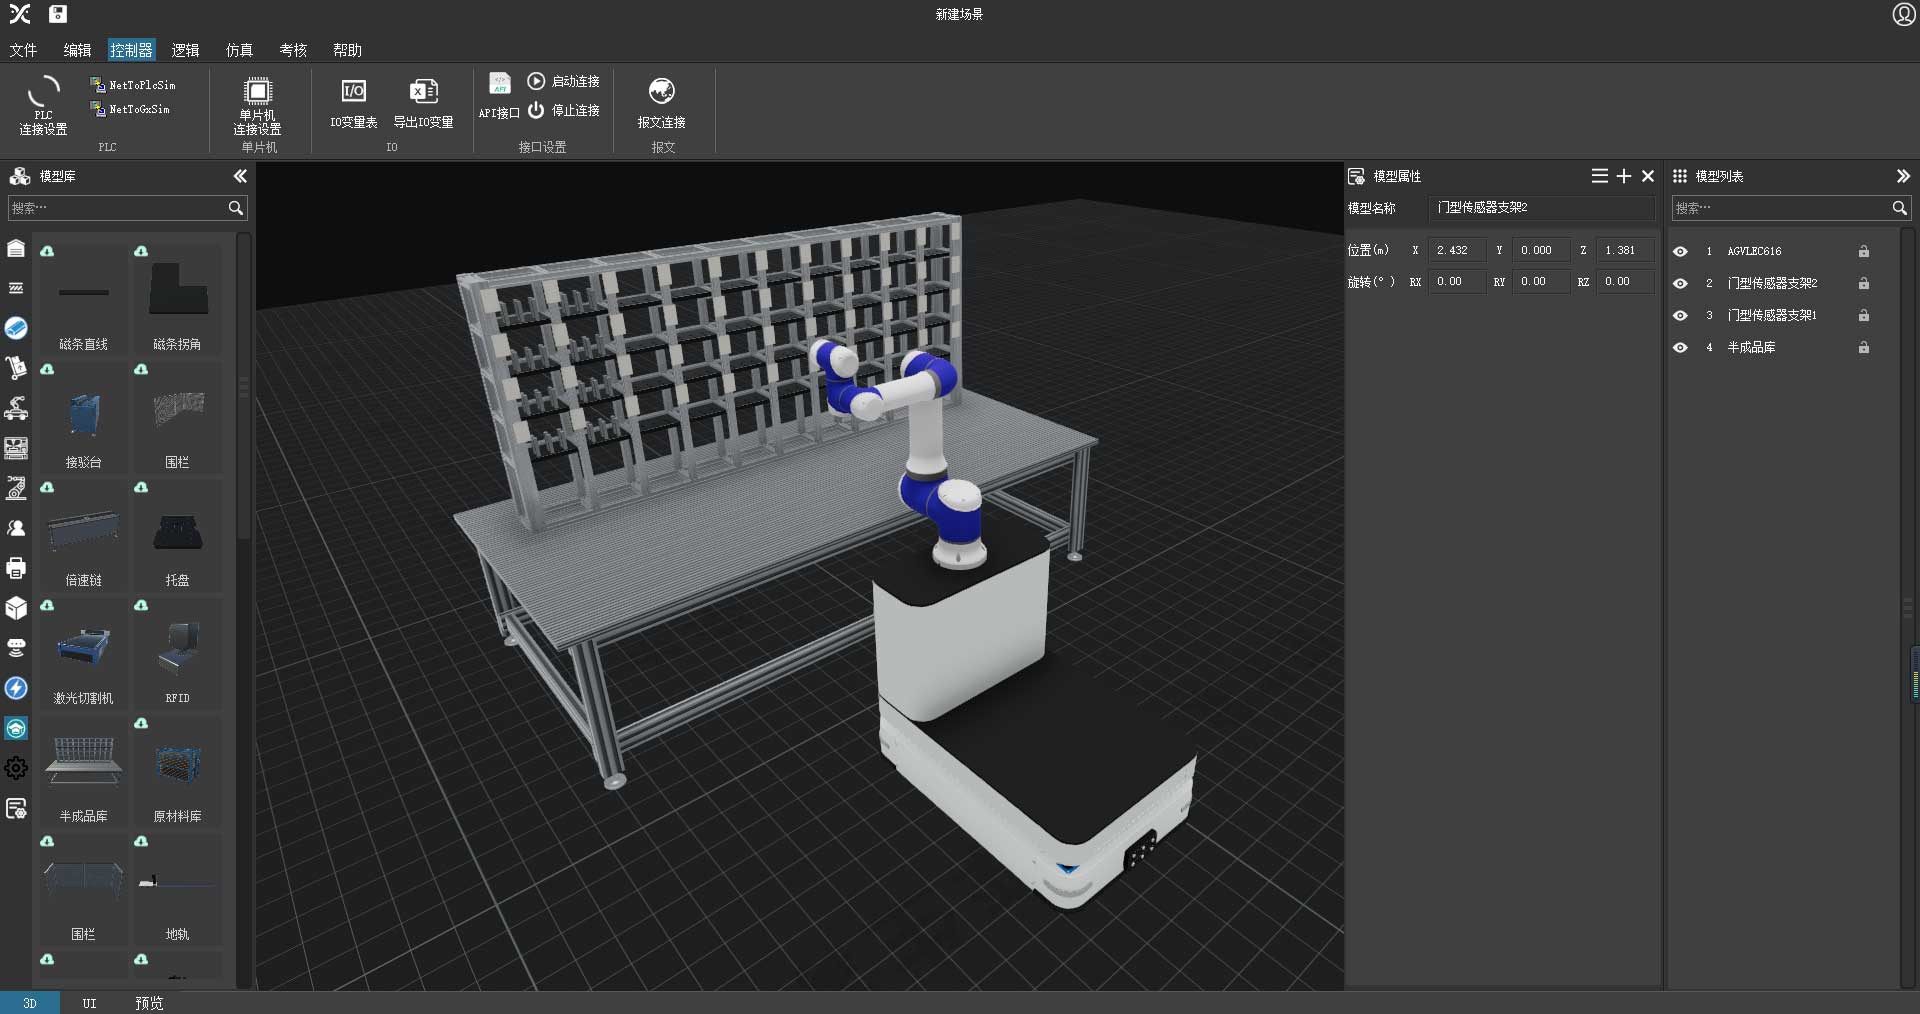
Plan arm trajectories and verify end-effector reachability
For complex grasping tasks, plan virtual trajectories and verify arm reach with the end tool installed before deployment, helping select an appropriate arm.
Mobile robot station layout and trajectory planning
Build scenes by dragging and dropping models, then lay out stations and plan routes in advance to validate transport paths.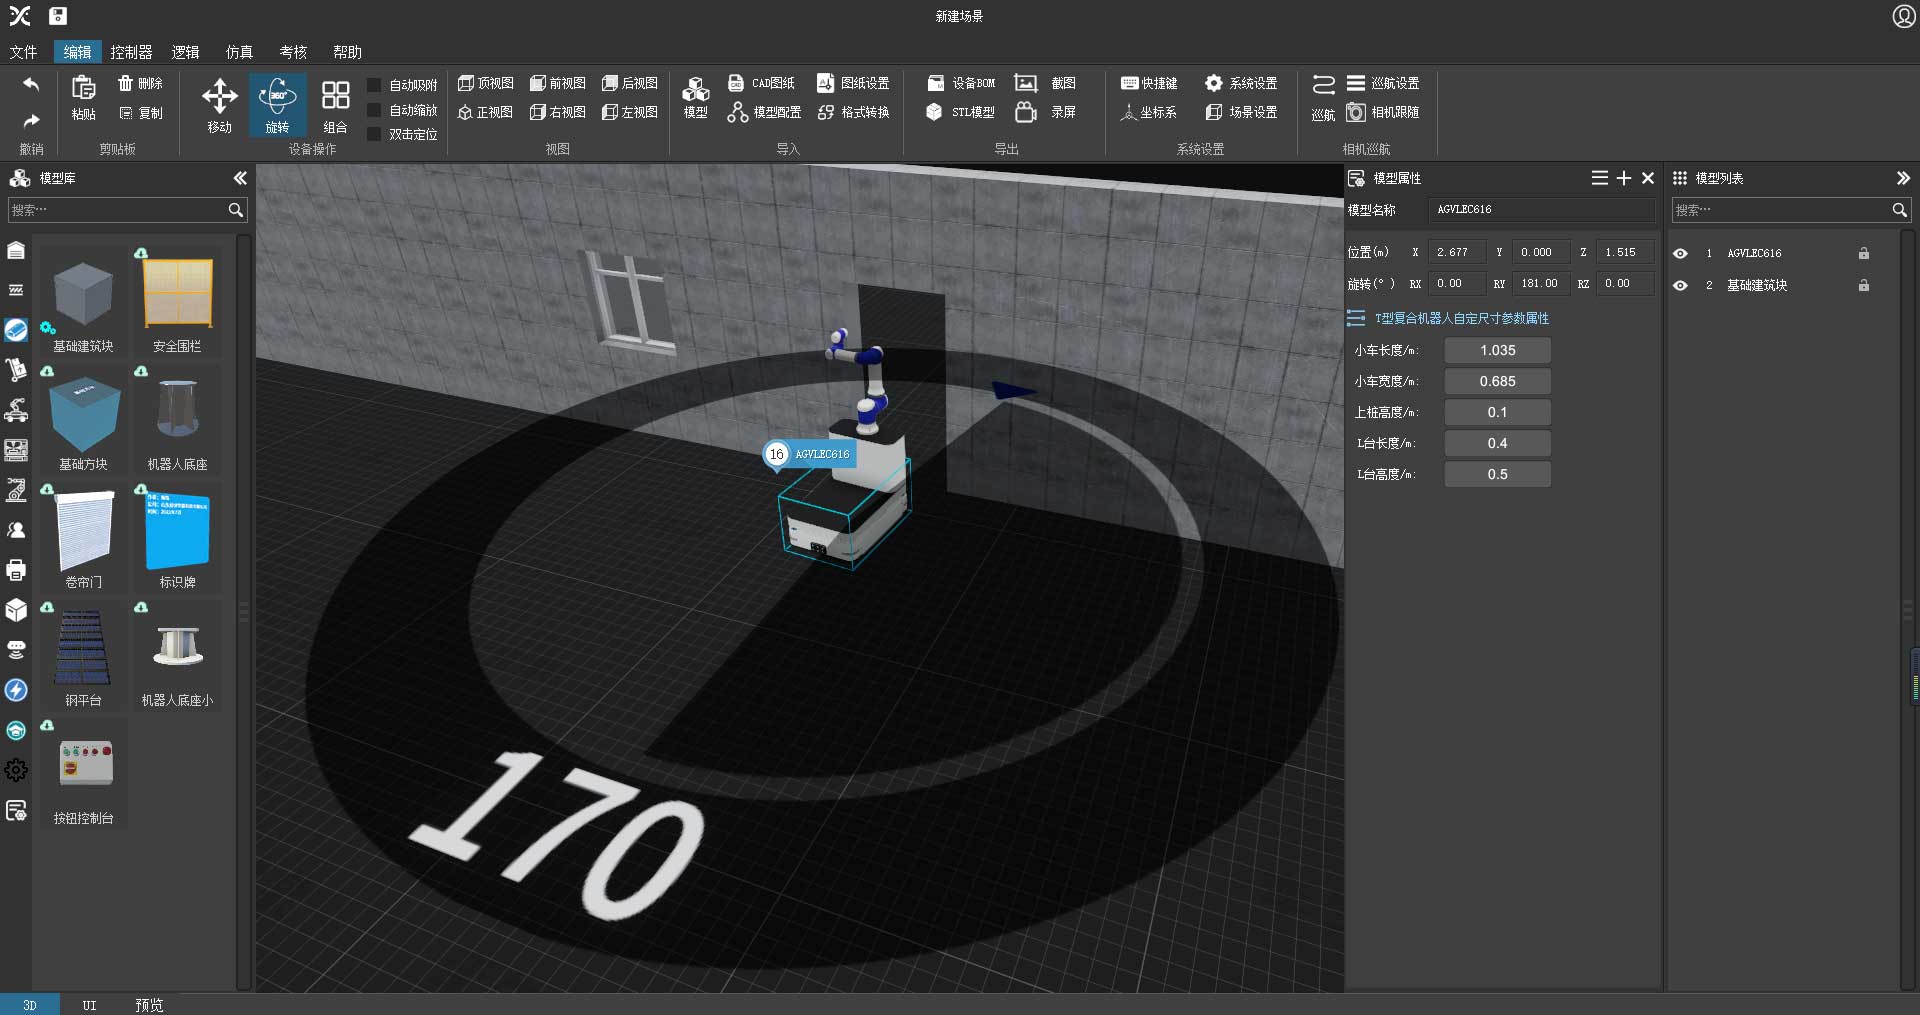
Validate mobile robot clearance and logistics feasibility
View mobile manipulator clearance envelopes and turning radii dynamically in real time. Quickly model roller doors, long corridors and narrow spaces to verify that the robot can pass through the project layout.